The World's First Robot- Cooked Mapo Tofu
June 22nd, 2026
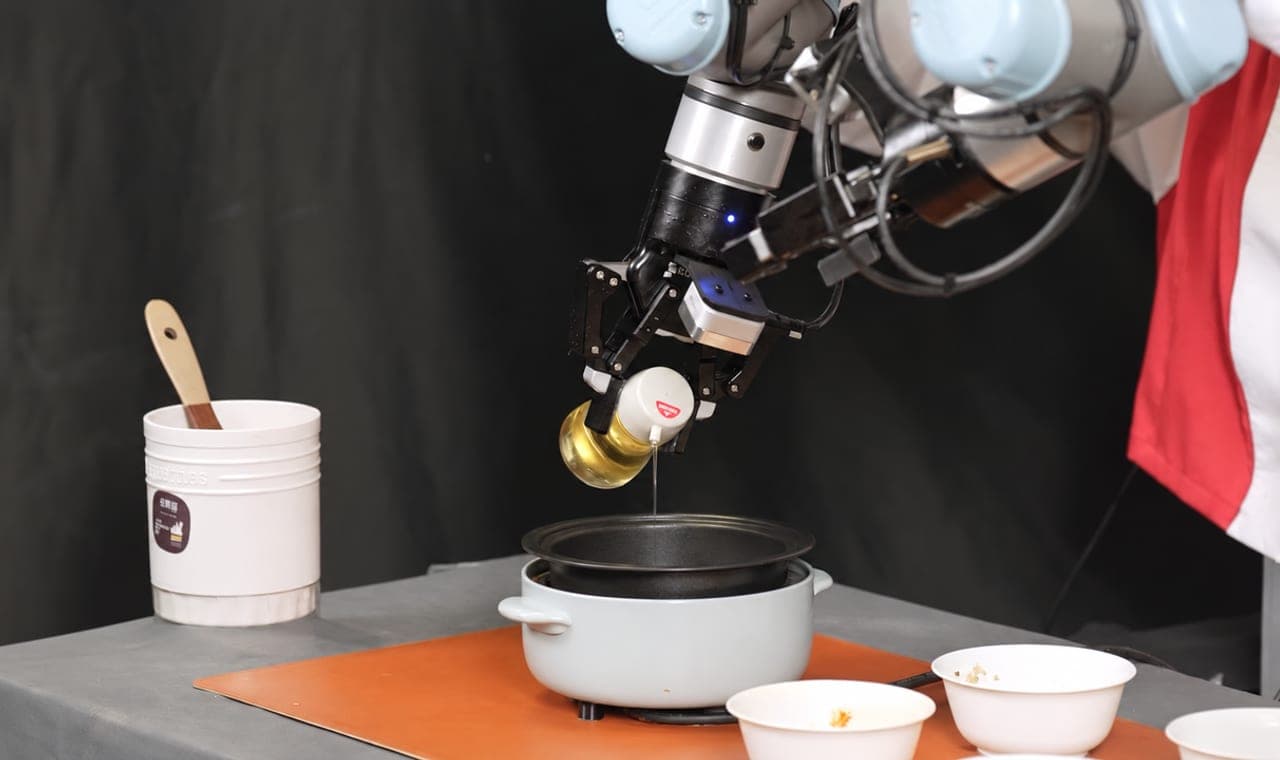
In the past June, PokeBot prepared a dish of Mapo Tofu—a 9-minute, fully autonomous, long-horizon, dexterous manipulation cooking task deployed entirely on real hardware. We chose Mapo Tofu because it captures the very essence of physical manipulation challenges in robotics:
「The Long Horizon」: Compounding Complexity
Over the course of nine continuous minutes, dozens of tightly interconnected steps leave no room for divergence. A minor discrepancy early on can compound down the task execution chain, posing a formidable challenge to long-horizon sequential planning and unbroken physical state tracking.
「The Dexterity」: Deformable Precision & Fine Force Control
Tofu is soft, fragile, and prone to deformation under the slightest load—far from a forgiving object for robotic manipulation. Slicing it cleanly demands millimeter-level precision with delicately calibrated cutting force, setting a high bar for closed-loop, fine force control that approaches the nuanced dexterity of human hands.
「The Dynamic」: Real-Time Perception & Adaptive Closed-Loop Control
As tofu breaks from whole blocks into bite-sized cubes and minced meat transitions from raw to seared, the physical scene continuously shifts. The robot cannot rely on static pre-programming; it must intuitively perceive what is unfolding in the wok in real time, grounding its observations to dynamically adapt its manipulation policies on the fly.
「The Heterogeneous」: Multi-Tool Affordance & Autonomous Error Recovery
Throughout the process, the robot seamlessly orchestrates a diverse array of instruments—knives, spatulas, stove controls, and seasoning bottles. Moving far beyond fixed routines, it must ground high-level semantic instructions into sequential task allocations while autonomously diagnosing anomalies, self-correcting, and retrying policies whenever physical perturbations arise.
「The Precision」: Sub-Millimeter Regrasping & Clearance Insertion
Actions such as in-hand knife reorientation and slotting the blade back into a knife block demand uncompromising positional accuracy. The robot must guide thin, hazardous tools into narrow millimeter-scale clearances—where even an imperceptible angular error can cause collisions or failure.
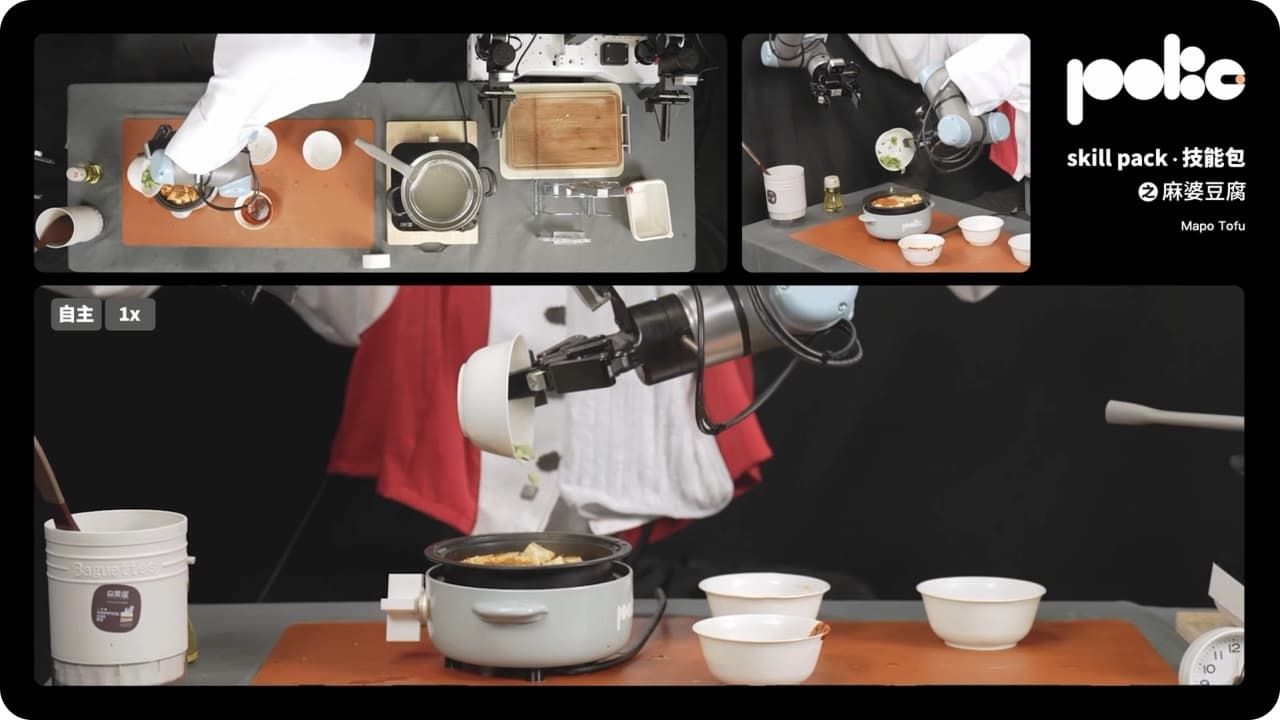
Globally, prior public demonstrations of robotic cooking have largely been confined to isolated, short-duration tasks. In achieving fully autonomous, long-horizon manipulation just three months after our founding, PokeBot has demonstrated levels of dexterity and generalization that stand at the forefront domestically and within the top tier worldwide. Beyond cooking mapo tofu, PokeBot simultaneously demonstrated a suite of demanding manipulation tasks—including garment folding, threading zip ties, and tying sachet drawstrings. Together, these benchmarks span the essential frontiers of robotic manipulation: deformable object handling, sub-millimeter visual-tactile alignment, and multi-step, long-horizon task execution.
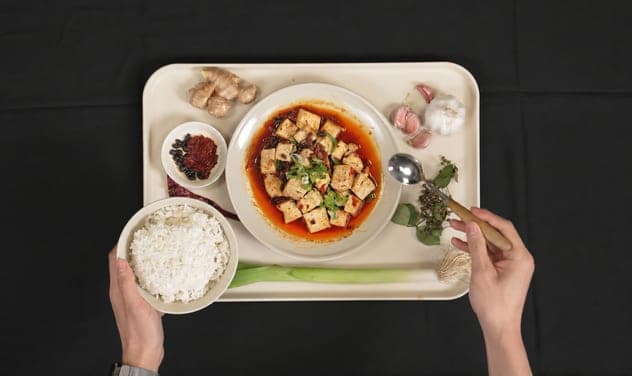
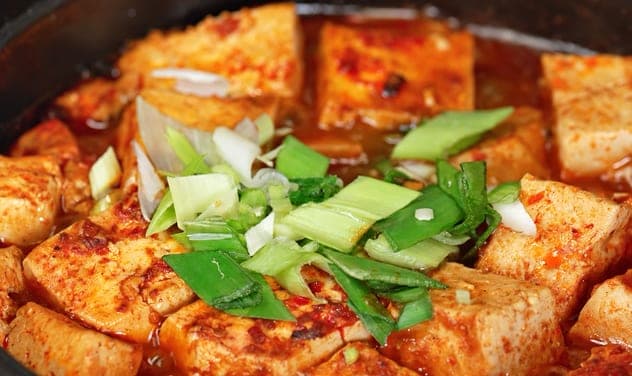
These demonstrations are not the fruit of isolated, single-point breakthroughs; Rather, they reflect the concentrated synergy of an integrated, full-stack technological architecture. Within less than six months of our founding, PokeBot has established an end-to-end technological pipeline—spanning foundation models, real-world reinforcement learning, proprietary data collection hardware, and training pipelines for complex, long-horizon tasks. Simultaneously, we have assembled an exceptional team uniting world-class talent across foundation models, RL, embodied agents, robotic form, hardware systems, product development, and commercialization. Looking ahead, PokeBot will continue to advance the co-design and joint evolution of embodied foundation models and robotic hardware.